Description
Optical Incremental Rotary Encoder 400 PPR, 5–24V
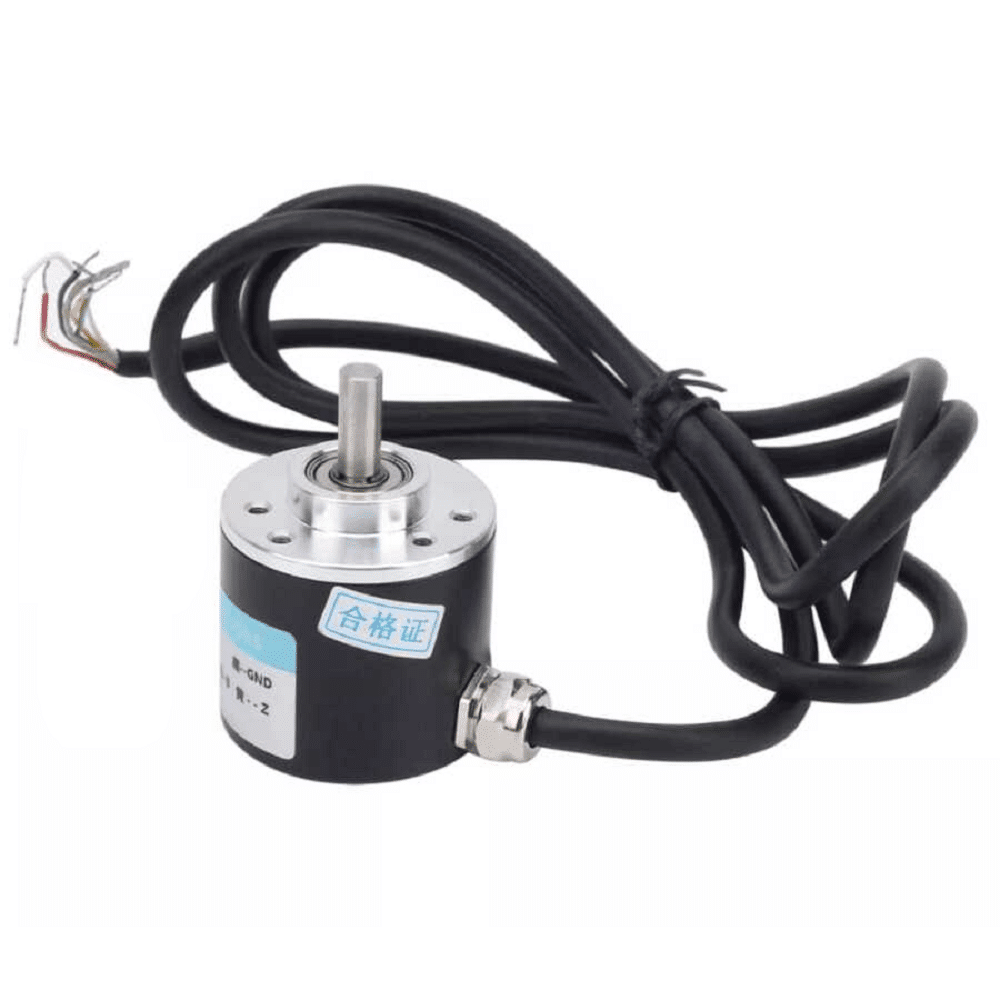
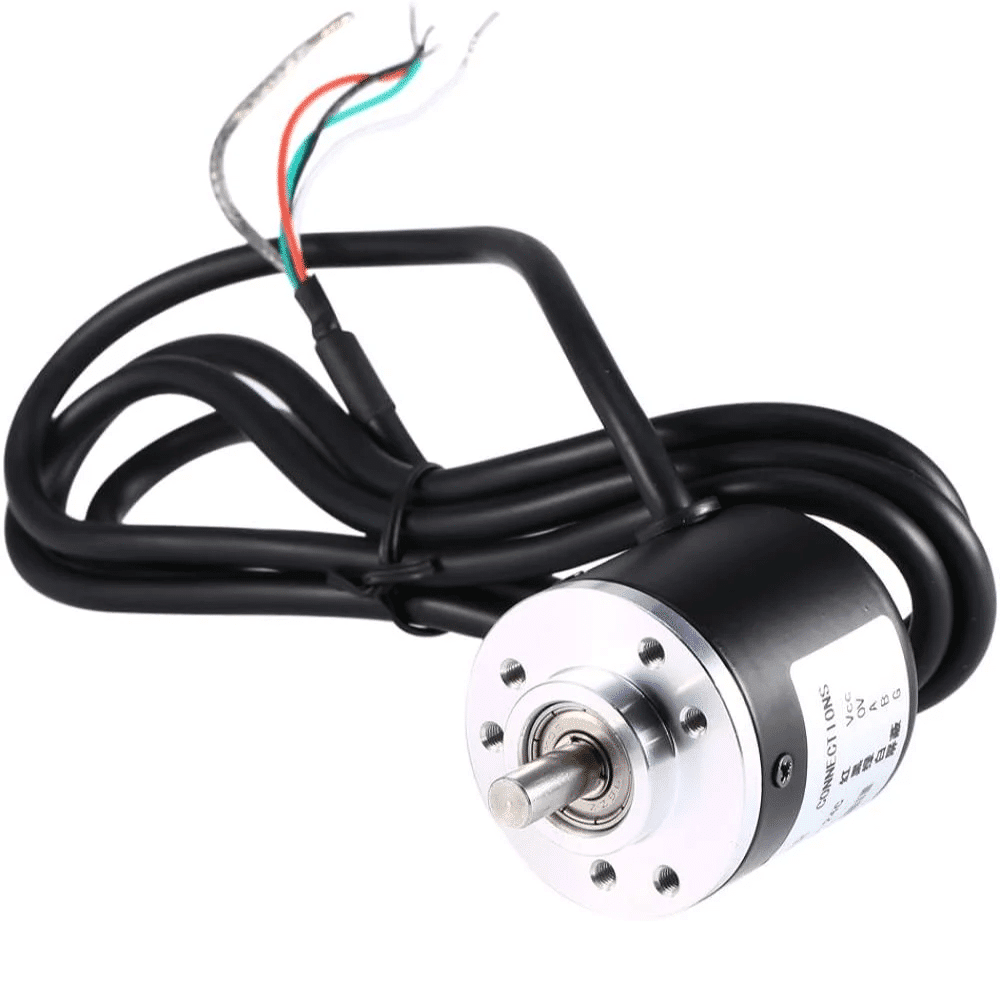
This compact optoelectronic incremental encoder provides 400 pulses per revolution (PPR) through two quadrature channels (A/B) and one index channel (Z). Its NPN open-collector outputs make it suitable for PLCs and microcontrollers. The encoder accepts a 5–24 V DC supply and has a sturdy Ø 6 mm shaft.
🔧 Technical specifications
- Resolution: 400 PPR (1,440 A/B quadrature counts per revolution, as listed)
- Channels: A and B (quadrature); Z index (1 pulse/revolution)
- Output: NPN open collector, maximum 30 V, 50 mA
- Supply: 5–24 V DC; typical current consumption 20 mA
- Maximum frequency: 5 kHz recommended
- Angular accuracy: 0.9°
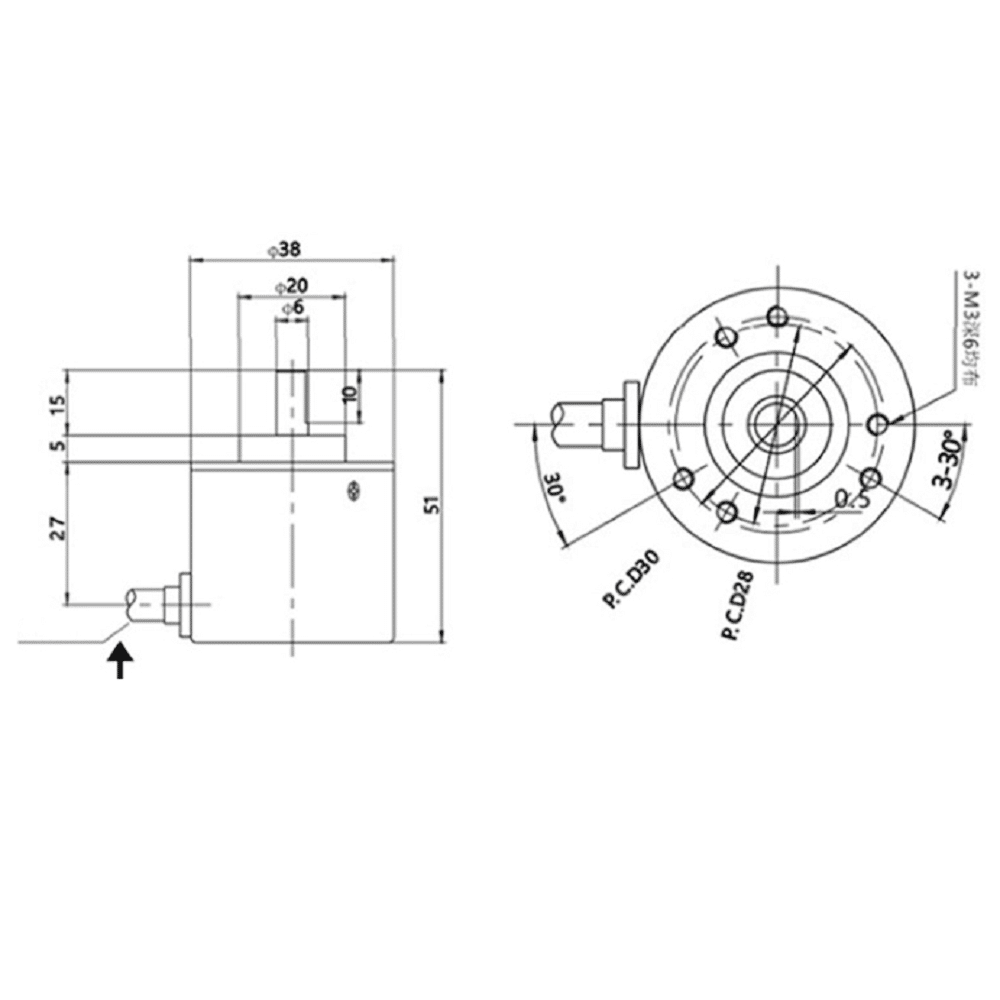
- Shaft: Ø 6 mm, 16 mm long, with flat
- Housing: robust metal, Ø 38 × 18 mm thick
- Mounting: three Ø 3.5 mm holes on a Ø 30 mm circle
- Operating temperature: −10 °C to +70 °C
- Ingress protection: IP50
💡 Typical applications
- Speed and position measurement on spindles or motorized shafts
- Servo-motor control and position feedback
- Industrial automation, robotics, and CNC
- Quadrature input for Arduino, PIC, STM32, and other microcontrollers
- Control systems for lifts, conveyors, and pumps
🛠️ Pinout and connections
| Pin | Function | Note |
|---|---|---|
| VCC | +5–24 V DC | Power; filter with a 0.1 µF / 50 V capacitor |
| GND | Ground | Common reference |
| A | Channel A output (open collector) | Use a 4.7–10 kΩ pull-up to VCC |
| B | Channel B output | Same pull-up recommendation |
| Z | Index output (1 pulse/revolution) | Same pull-up recommendation |
- Connect VCC and GND to power the encoder.
- Connect A, B, and Z to inputs with internal or external pull-ups.
- Configure the MCU/PLC to detect rising or falling edges on A/B and use Z as the zero-reference index.
- Check the signals with an oscilloscope or logic analyzer: approximately 50% duty cycle and an ideal 90° phase offset between A and B.
Tip: For higher speeds, keep signal wires short and use shielding to reduce EMI interference.